Best Innomotics Reducers for High-Performance Industrial Drive Systems
2026-09-28
Most drive system failures don’t start in the motor—they start in the reducer. That’s why top engineers are paying closer attention to Innomotics reducers, which often determine whether a high-performance industrial drive runs smoothly or stalls under load. At Soochee, we’ve seen firsthand how the right reducer selection can cut downtime and extend equipment life. This guide breaks down the best Innomotics reducers for demanding applications, so you can match torque, speed, and mounting requirements without guesswork.
Torque Density That Redefines Compact Drive Design
Most compact drives force a compromise: shrink the footprint and watch torque fall off a cliff. This one doesn't. The magnetic circuit has been reworked from the ground up, packing more flux into a volume that would have been dismissed as too small a decade ago. The result is a torque density that lets you drop a smaller motor into the same envelope and still hit your load curve.
That shift doesn't come from exotic materials or a marginal gain in winding fill. It comes from rethinking where the copper sits, how the stator teeth breathe, and what happens at the air gap under load. Thermal behavior changes too — less mass, same work, so the heat path matters more than ever. Engineers who've run back-to-back tests on legacy designs tend to notice the difference in the first acceleration ramp.
For machine builders, it means things like shorter cantilevers, tighter tooling clusters, and fewer gearbox stages. The drive stops being the bottleneck in the CAD model and starts being a part you can place and forget. That's the whole point: density that changes what the mechanism can look like, not just the motor catalog number.
Precision Gear Geometry for Near-Silent Operation
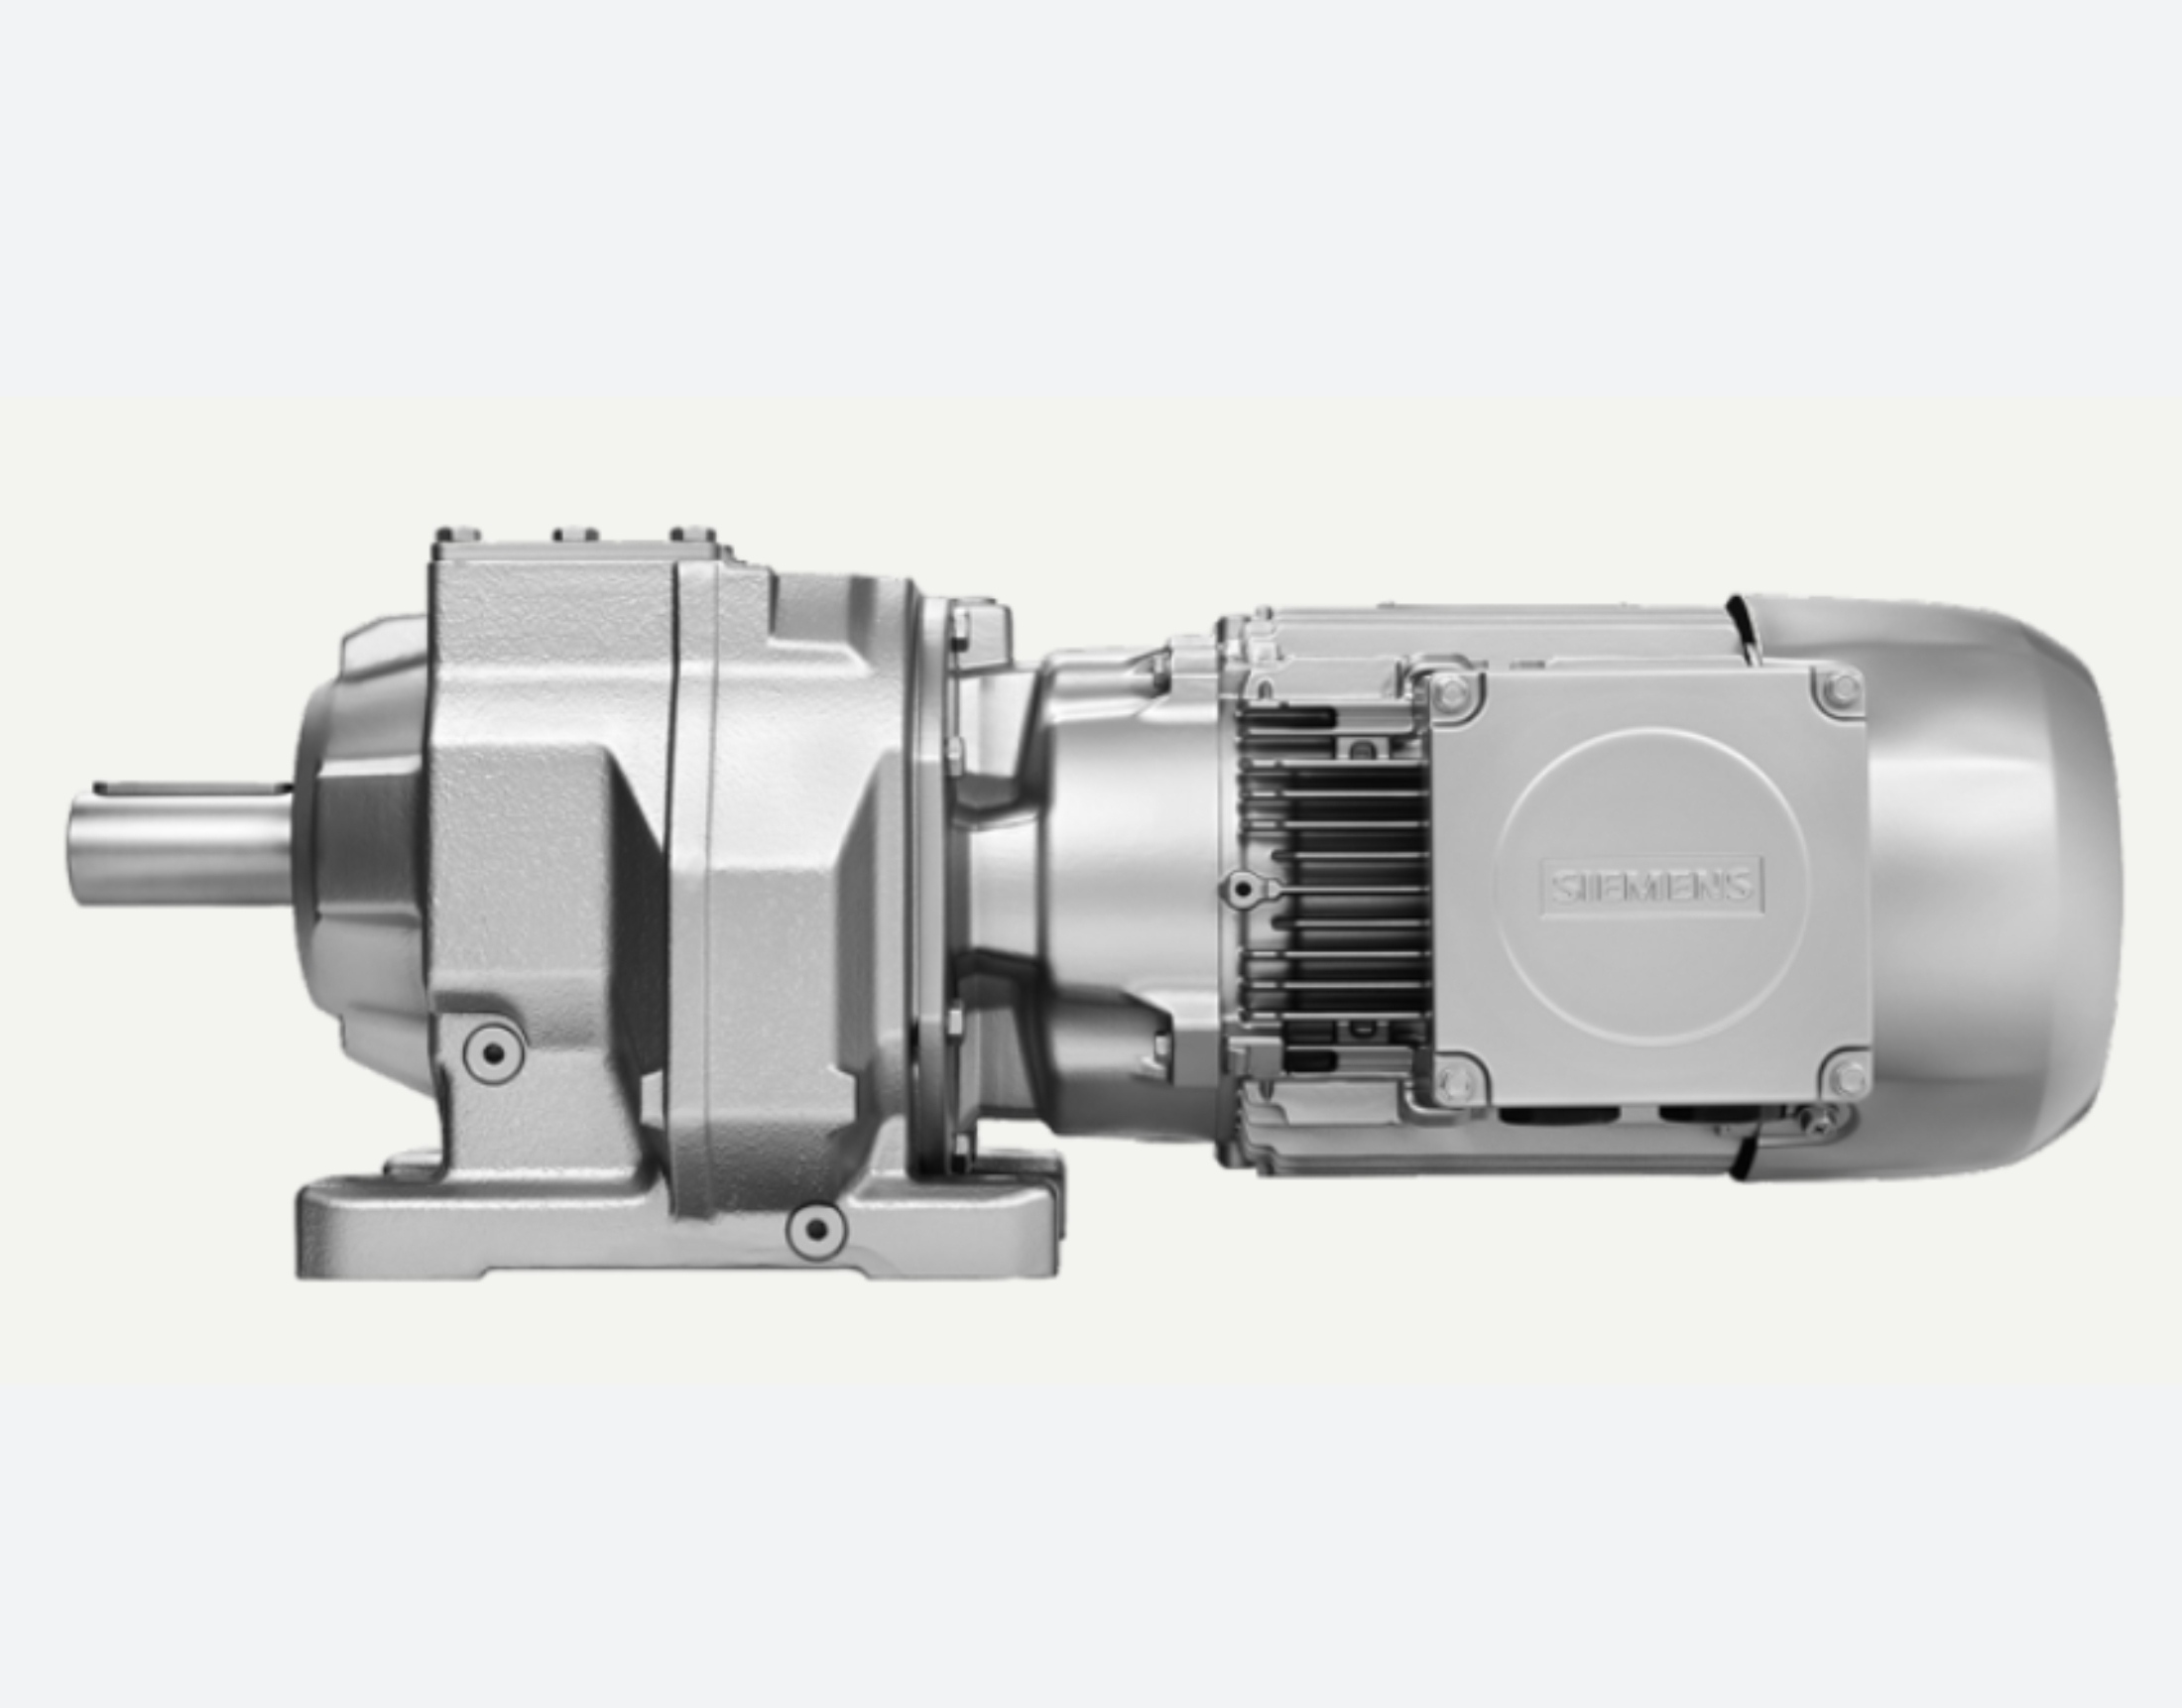
The dominant source of gear whine in high-speed transmissions is transmission error, a small deviation between the theoretical and actual angular position of the driven gear. To keep this below the audible threshold, tooth flanks are not left as simple involutes. Instead, they receive deliberate micro-modifications—typically a few microns of tip relief and root relief—so that the entering and exiting teeth deflect smoothly under load instead of slamming into contact. This profile crowning shifts the load gradually across the mesh cycle, suppressing the impulsive excitation that would otherwise radiate as a high-pitched tone.
Helix angle plays an equally decisive role. A carefully chosen spiral angle increases the axial contact ratio, meaning two or more teeth share the load over a longer portion of the rotation. This overlap damps the stiffness variation between single and double tooth contact, which is the main driver of gear rattle. However, pushing the helix angle too far introduces axial thrust loads and demands more robust bearings. For near-silent operation, the geometry is tuned so that the total contact ratio—transverse plus axial—stays above roughly 2.0, while keeping the face width sufficient to avoid edge loading.
Beyond the macro geometry, surface integrity matters at the scale of a wavelength. Grinding and honing leave a characteristic lay on the tooth flanks. If that texture has a periodic waviness matching the tooth passing frequency, it can amplify narrowband noise even when the gear is otherwise precise. Final finishing therefore focuses on reducing low-order waviness and ensuring a uniform contact pattern under light load. The goal is not just a geometrically accurate gear, but one whose microscopic deviations do not create a coherent, repeatable excitation pattern.
Thermal Stability Under Continuous Heavy Loads
Thermal stability isn't a spec you'll find printed on a datasheet. It shows up after the third hour of running a converter at full rated current while the enclosure fan hums at a fixed speed and the room temperature creeps past 35°C. What separates a robust design from a marginal one is how little the internal hotspot shifts once the whole assembly reaches saturation. A rise of two or three degrees after that point might be fine; a rise of fifteen means the thermal path is already choking.
Many failures blamed on overheating actually come from thermal expansion mismatch, not raw temperature. Copper traces expand more than the ceramic or FR4 beneath them. Under repeated heavy load cycles, the solder joints at the edges of a power device flex microscopically. Over weeks of continuous duty, those flex points develop voids. Voids increase local resistance, which increases local heating, which accelerates void growth. The loop is quiet and slow, but it ends in a hot spot that no infrared camera would have predicted during a short bench test.
One practical way to check true stability is to monitor the case temperature of the main switching device during a long soak test—at least four to six hours, not the usual twenty minutes. If the case temperature keeps creeping upward after airflow and load are held constant, the internal thermal resistance is likely rising. Units with direct-bonded copper substrates and carefully matched CTE layers tend to plateau early. That plateau, not the peak number on a thermal image, is the sign the design can handle continuous heavy loads without slowly cooking itself.
Matching Reducer Stages to Complex Motion Profiles
Industrial motion rarely follows a simple trapezoidal velocity curve. In pick-and-place systems, the load accelerates hard, reaches peak speed for a few milliseconds, and then slams to a stop with a controlled jerk. A single-stage planetary reducer may offer the stiffness needed for the rapid starts, but its limited torque multiplication can force the motor to operate near saturation during the peak phase. Adding a second stage boosts torque and reduces reflected inertia, yet it also introduces more compliance and a slight increase in backlash, which shows up as overshoot at the end of the move. The trick is to look at the exact shape of the motion profile: if the dwell time is short and the reversal is aggressive, a preloaded two-stage unit often outperforms a larger single-stage design because the extra reduction lets the motor ride closer to its efficient speed band.
Complex profiles that include sine-on-acceleration or S-curve segments place different demands on the gearbox. Those smooth ramps reduce peak torque but extend the time spent in the high-acceleration region, making thermal behavior and lubrication more critical. Here, a three-stage reducer might seem like overkill, but if the load has high inertia and the profile includes a long constant-velocity section, the extra stages lower the motor's speed requirement and keep heat buildup manageable. However, each stage adds a small amount of lost motion. For applications like robotic wrist joints or CNC rotary tables, where the motion profile reverses direction several times per second, even a few arc-minutes of backlash can create visible path errors. In those cases, a harmonic or cycloidal reducer with a single high-ratio stage often provides a better match because its inherent preload eliminates most of the lost motion while still delivering the needed torque density.
Another overlooked factor is the profile's jerk limit. High jerk settings let the machine reach target speed faster, but they excite the reducer's internal resonances. A two-stage inline planetary reducer with a stiff housing and minimal axial play can damp these vibrations better than a cheap single-stage unit with a floating ring gear. On the other hand, if the motion profile includes frequent dwells and short, sharp indexing moves, a low-ratio single stage paired with a larger servo motor might win on both cost and dynamic response, because the lower gear inertia allows the motor to change speed without fighting the gearbox's own mass. The key is not to count stages in isolation but to simulate the full motion cycle with the reducer's inertia, stiffness, and efficiency mapped against the required velocity, acceleration, and jerk at each time step. That way, the chosen stage count emerges from the profile itself rather than from a generic torque calculation.
Material Choices That Extend Service Intervals
Selecting the right materials isn't just about upfront cost or tensile strength—it's about how those choices interact with real-world cyclic loading, temperature swings, and fluid exposure. Take bearing alloys, for instance: a switch from a basic tin-babbitt to an aluminum-tin composite can push lubrication intervals from twelve months to thirty-six without any change in shaft alignment or housing design. The key is matching the material's fatigue limit and embeddability to the actual debris load in the oil, rather than chasing a higher hardness rating on a spec sheet.
Elastomer seals and gaskets often get overlooked, yet they dictate most unscheduled downtime in gearboxes and hydraulic systems. Replacing a standard nitrile O-ring with a hydrogenated nitrile or fluorocarbon compound adds maybe two percent to the bill of materials, but it eliminates the hardening and cracking that force mid-cycle replacements. Similarly, upgrading shaft sleeves from carbon steel to a plasma-sprayed ceramic coating removes the fine pitting that gradually widens clearances and accelerates wear on every downstream component.
The real win comes from thinking in terms of paired materials rather than individual upgrades. A cast iron housing mated with a stainless steel fastening system creates galvanic corrosion that no single coating can fully prevent—but switching to a duplex stainless fastener or an isolating bushing removes the need for annual inspection. When material choices are mapped to the actual failure modes seen in service, the interval between major overhauls often doubles without any change to operating conditions.
Retrofitting Legacy Lines Without Downtime Overruns
Older production lines often carry the hidden weight of undocumented modifications, worn-out drives, and control logic that no one wants to touch during a shutdown. The usual approach—cut over on a weekend and hope for the best—works until a forgotten signal or mismatched I/O map turns a six-hour window into a thirty-hour scramble. Retrofitting without overruns starts by treating the existing line as a live system, not a blank slate. That means building a detailed electrical and functional audit first, capturing every sensor, actuator, and interlock as it actually behaves, not as the original drawings claim.
A staged retrofit breaks the work into modules that can be tested against the running process without forcing a full stop. For example, new safety relays or remote I/O blocks can be mounted and wired to field devices while the old PLC still governs, then switched over one circuit at a time. Each switchover is verified with forced outputs and loop checks before the next segment is touched. When the final cutover does happen, it is usually a matter of flipping a selector rather than re-terminating hundreds of wires under pressure.
The difference between a clean retrofit and a costly overrun often comes down to how well the team rehearses the sequence. Dry runs with the line in manual mode, spare parts staged at the point of use, and a clear rollback plan for each phase keep surprises small. Legacy lines rarely reward speed; they reward preparation. Slowing down the planning while keeping the execution windows tight is what lets a retrofit finish on schedule without holding production hostage.
FAQ
They combine rugged gear geometries with tight manufacturing tolerances, so you get less backlash and smoother torque transfer. The housings are designed to handle peak loads without flexing, which matters a lot when your line speed changes frequently. It's not just about catalog ratings; the reducers hold up under real start-stop cycles.
Start with the actual duty cycle, not just the motor nameplate. Look at peak torque, radial loads on the output shaft, and ambient temperature. Innomotics application engineers usually ask for a load profile and then recommend a size that leaves a comfortable service factor. Oversizing by a bit is cheaper than downtime.
Yes, certain series come with sealed housings and coated surfaces for moisture or abrasive dust. You can specify food-grade lubricants or added shaft seals. In cement plants and food processing, we've seen them run for years without opening the gear case.
Keep an eye on oil condition and temperature. Most units have inspection ports for quick sampling. Re-grease bearings on schedule, but avoid over-greasing as it can push seals out. If you notice increased noise or vibration, check alignment before blaming the gears. A simple alignment fix often extends life significantly.
Modern helical-bevel or planetary designs reduce friction losses. When paired with a high-efficiency motor, the system can run cooler and use less power. It's not a massive gain per unit, but across a plant with dozens of drives, the savings add up. The real efficiency win is fewer unplanned stops.
Mining, material handling, automotive assembly, and packaging lines. Basically anywhere you need variable speed with high torque and cannot afford frequent gearbox swaps. They also work well in crane and hoist applications where controlled acceleration matters.
Yes, they use standard IEC or NEMA mounting flanges and shaft dimensions. You can bolt them to most premium efficiency motors. Just ensure the input flange and shaft tolerances match. The Innomotics team can provide adapter kits if needed.
They typically provide alignment guides, torque specs, and sometimes on-site supervision for large projects. Their application engineers can help with thermal checks and load tests. If you have a custom integration, they may arrange a joint commissioning with your controls team.
Conclusion
Innomotics reducers push the boundaries of what compact industrial drive systems can achieve. Their torque density eliminates the usual trade-off between footprint and force, letting engineers pack more power into tighter machine envelopes without sacrificing rigidity. The gear geometry is cut and finished to such close tolerances that high-speed operation becomes remarkably quiet, which matters on production floors where noise directly affects worker comfort and communication. Under continuous heavy loads, thermal stability prevents performance drift; the housing and lubrication system work together to shed heat predictably, so the reducer holds its rated torque even when the line never stops.
Matching reducer stages to complex motion profiles is not a one-size-fits-all exercise, and Innomotics offers enough configuration flexibility to avoid oversizing or undersizing for rapid acceleration, dwell, and reversal cycles. Material choices extend service intervals by resisting micropitting, wear, and lubricant breakdown, which means fewer planned shutdowns and lower lifetime cost. For older installations, retrofitting legacy lines without downtime overruns is a practical strength: the modular mounting interfaces and adapter kits let teams swap in a modern reducer during a normal maintenance window, restoring throughput and efficiency without tearing apart the surrounding automation.
Contact Us
Contact Person: Jenny Jaa
Email: [email protected]
Tel/WhatsApp: 0086 152 9510 6006
Website: https://www.china-motor-supplier.com